← All projects 
Point Cloud Processor
What it is
- — A desktop application that detects planes inside point clouds and exports per-plane information — built as a graduation project with 3 collleagues.
Features
- — Load .ply files, zipped exports or folders of previous exports.
- — Automatic plane detection with RANSAC on the Open3D backend.
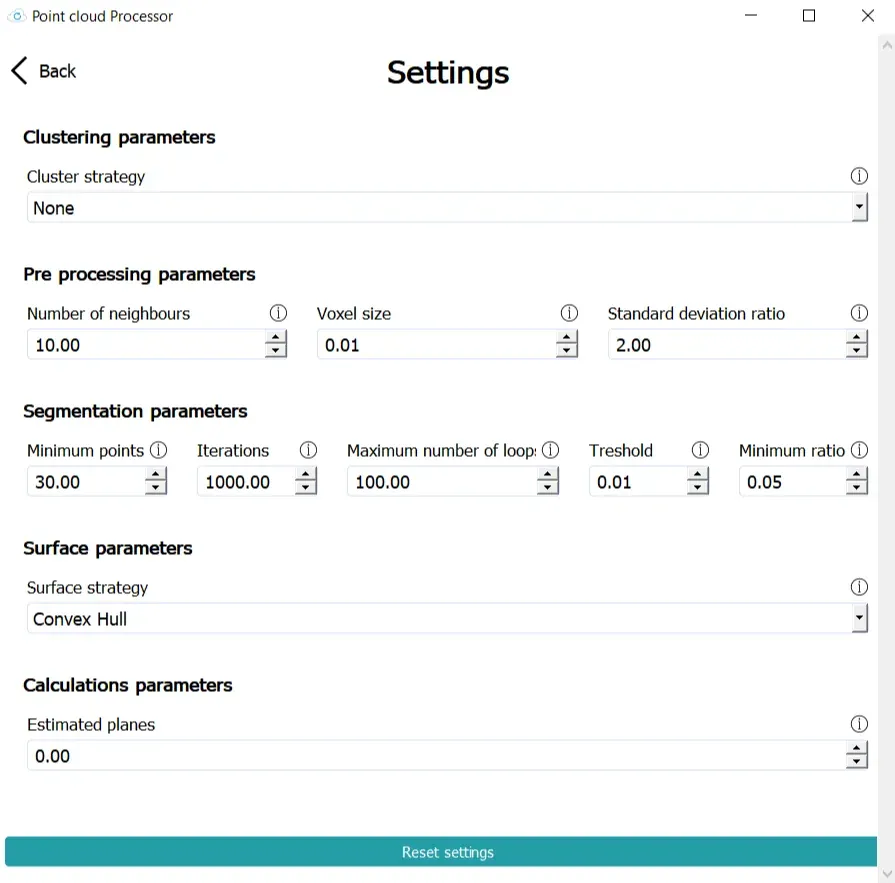
- — Optional clustering using DBSCAN or agglomerative clustering.
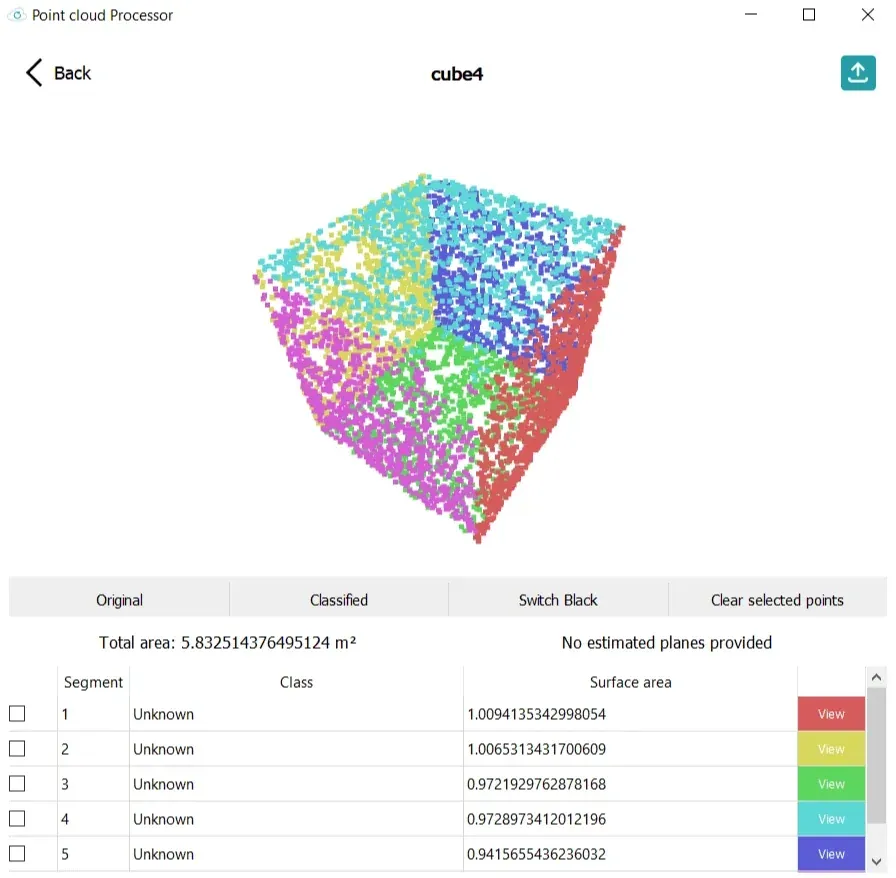
- — 3D visualisation of the original and segmented point clouds.
- — Surface area, class assignments and estimated segmentation accuracy.
- — Merge, delete and recolour individual segments.
- — Export ZIPs containing the planes and a CSV with surface areas.
Built with
- — Python + PyQt5 front-end, Python + Open3D/Scikit-Learn model, pluggable clustering strategies.